Hi, I'm Lyuxing! Lyuxing's professional portrait

Lyuxing He in graduation regalia at the CMU Robotics Institute

I am a Founding Machine Learning Engineer at SafeWorld, working on helping robots to deploy safely and responsibly.

In the meantime, I am an independent researcher exploring the intersection of Computer Vision and Robot Learning. I'm particularly interested in developing methods that enable robots to acquire generalizable manipulation skills from visual demonstrations through geometric and spatial reasoning.

Previously I was a Master student at Carnegie Mellon University (CMU) Robotics Institute and a member of Robots Perceiving and Doing (RPAD) Lab, advised by Prof. David Held. I obtained my Bachelor of Science in Electrical Engineering with a minor in Computer Science from University of Illinois at Urbana-Champaign with Highest Honors. During my undergraduate studies, I joined the Human-Centered Autonomy Lab as a research assistant, advised by Professor Katie Driggs-Campbell. I also joined The Chinese University of Hong Kong and the Ren Lab as a summer visiting scholar, advised by Professor Hongliang Ren.

You can contact me at lyuxingh at alumni dot cmu dot edu.

Publications

Publications and Pre-Prints

Enabling Intelligent Procedures: Endoscopy Dataset Collection Trends and Pipeline

2024, Handbook of Robotic Surgery

Enabling Intelligent Procedures: Endoscopy Dataset Collection Trends and Pipeline

Lyuxing He, Huxin Gao, Hongliang Ren

An end-to-end surgical data automation and scene-reconstruction pipeline that assembles an in-vivo GI dataset and trains a pose-free NeRF to deliver dense 3D representations despite specular surfaces and limited data.

2026, ICRA · Vienna

Disentangled Point Diffusion for Precise Object Placement

Lyuxing He*, Eric Cai*, Shobhit Aggarwal, Jianjun Wang, David Held

A hierarchical object-centric point diffusion framework that combines dense GMM global initialization with disentangled geometry and frame diffusion to deliver SOTA precision, multi-modal coverage, and generalization in both rigid and non-rigid placement tasks.

2026, Preprint

ParticleSplat: Self-supervised Object-centric Latent Particle Splatting

Lyuxing He, Daniel Guo, Elizabeth Terveen, Deepak Pathak, David Held, Tal Daniel

ParticleSplat is a self-supervised representation learning method using feedforward Gaussian splatting that learns 3D object decomposition without supervision or priors, enabling scene editing and robotic manipulation.

Projects

Projects and Cool Stuff

Auto-following Luggage Platform (AutoLug)

Undergrad Capstone Project

Auto-following Luggage Platform (AutoLug)

Lyuxing He, David Chen

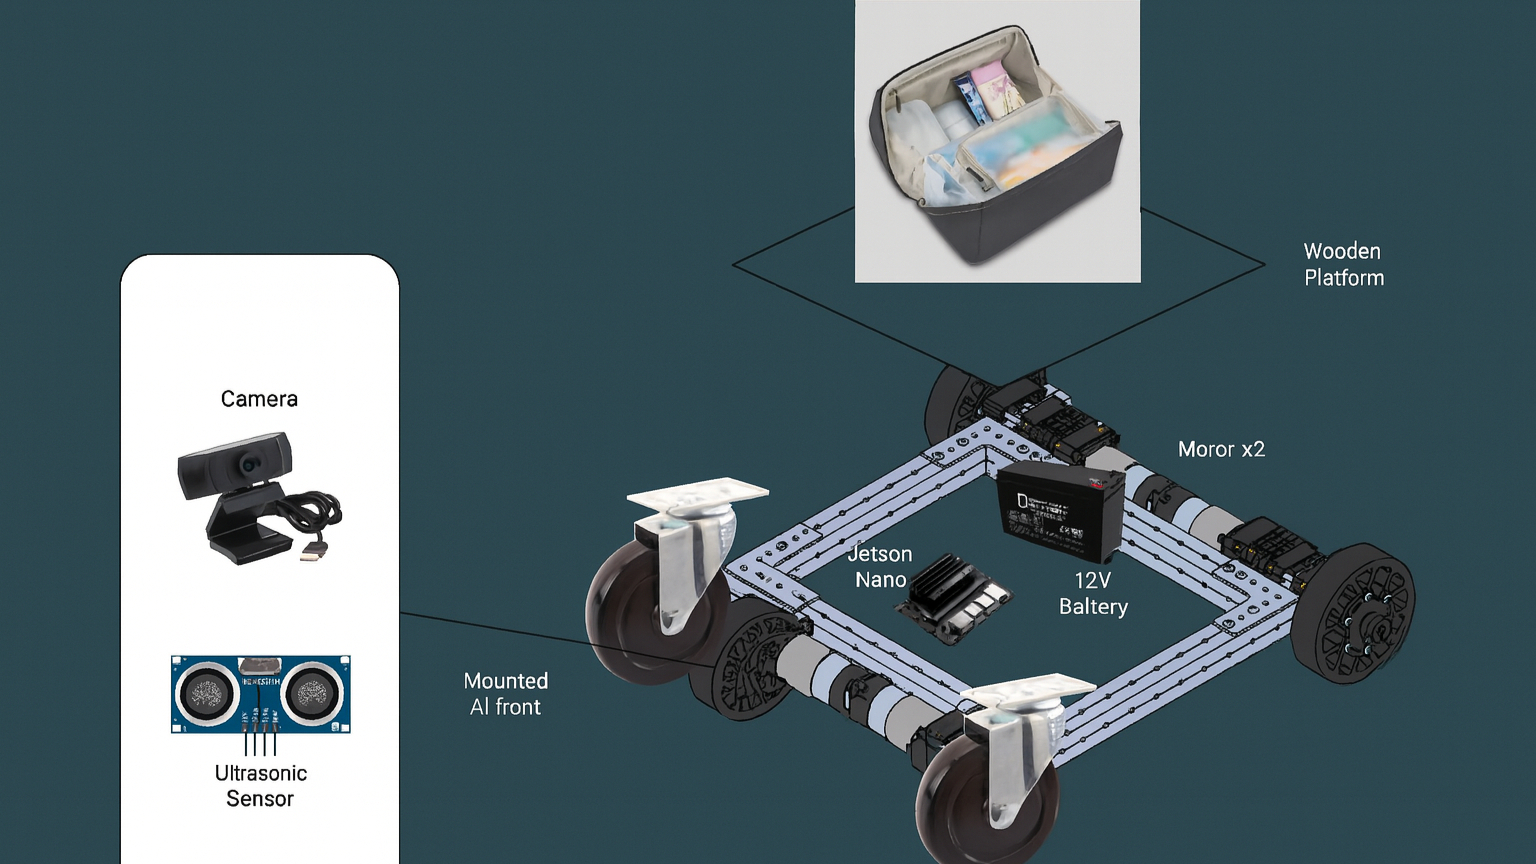
An auto-following luggage platform (AutoLug) that integrates owner registration and onboard vision-based identification to enable safe, collision-free following, offering excellent affordability, versatility across luggage types, and reusable platform functionality compared to conventional smart suitcases.

Experience

Education & Research

University of Illinois Urbana-Champaign

Aug 2019 – Dec 2023

B.S. in Electrical Engineering

Aug 2019 – Dec 2023
Computer Science minor · Highest Honors

  1. Aug 2022 – Dec 2023

    Undergraduate Researcher

    Human-Centered Autonomy Lab · Prof. Katie Driggs-Campbell

    Contributed to a marginalized importance sampling framework that combines real-world offline data with imperfect simulators for stable off-environment policy evaluation. The framework achieved state-of-the-art results in Sim2Sim benchmarks and was validated through Sim2Real experiments on a Kinova robotic arm.

  2. May 2022 – Aug 2022

    Research Assistant

    Mitra Research Group · Prof. Sayan Mitra

    Developed a web-based debugger for Verse, the group's autonomous-system verification tool, to support the design and analysis of autonomous vehicles. Evaluated Verse on a simulated GEM vehicle in Gazebo and on a physical GEM vehicle.

  3. Aug 2021 – Aug 2022

    Undergraduate Researcher

    National Center for Supercomputing Applications · Prof. André Schleife

    Built volumetric models from raw electron-density data and an interactive holographic rendering system controlled by remote hand gestures. Tuned the system for classroom teaching and outreach demonstrations to make materials science concepts easier to understand. Received NCSA recognition for outstanding undergraduate research.

  4. Aug 2021 – May 2023

    Lead Electrical Engineer

    Illini Air Shuttle

    Led electrical engineering work for student-built, small-scale eVTOL prototypes. Organized discussions on design constraints and thrust and weight estimates, and coordinated PCB design, 3D-printed component assembly, electronics soldering, and vertical-takeoff testing. Taught seminars on robot control systems and computer vision using the first working subscale model.

Research

The Chinese University of Hong Kong

Jun 2023 – Dec 2023

  1. Jun 2023 – Dec 2023

    Undergraduate Researcher

    Ren Lab · Prof. Hongliang Ren

    Built and deployed a semi-autonomous, ROS-controlled data collection system using an Olympus duodenoscope, producing the first in-vivo, in-cavity gastrointestinal dataset with complete ground truth for dense 3D reconstruction. Designed a monocular NeRF framework that separates diffuse and specular radiance to handle near-field lighting, fluids, and exposure changes in endoscopy. This work was published in Handbook of Robotic Surgery.

Education & Research

Carnegie Mellon University

Aug 2024 – May 2026

M.S. in Artificial Intelligence

Aug 2024 – Dec 2025

  1. Aug 2024 – May 2026

    Research Assistant

    Robots Perceiving and Doing Lab (R-PAD) · Prof. David Held

    Developed a hierarchical, object-centric point diffusion framework combining dense Gaussian mixture model (GMM) global initialization with disentangled geometry and frame diffusion, achieving state-of-the-art placement precision, multimodal coverage, and generalization across rigid and non-rigid placement tasks. This work was accepted to ICRA 2026.

    Developed ParticleSplat, a self-supervised, object-centric 3D representation learning framework that maps multi-view observations into compact latent particles and particle-aligned Gaussian splats. Trained through novel-view synthesis without segmentation supervision, the framework enables 3D object decomposition and controllable scene editing, while improving downstream robotic manipulation policies. This work is available as a preprint.
Industry Shenzhen, China

Makeblock

Feb 2021 – Jun 2021

  1. Feb 2021 – Jun 2021

    Electrical Engineering Intern

    Helped automate scoring for the MakeX Robotics Competition and led MakeX Starter competition design under the department manager's supervision. Assisted with parameter validation and CAD work for CyberPi microcontrollers, sensors, and other Makeblock electronics.

Industry Hangzhou, China

A4x AIoT

Feb 2024 – Aug 2024

  1. Feb 2024 – Aug 2024

    Research Intern

    Developed a Real2Sim framework using 4D Gaussian splatting and feature splatting to transform in-the-wild videos into simulation environments. Generated grounded reward functions to support scalable training of robotic manipulation foundation models beyond traditional human-demonstration pipelines.

Industry Palo Alto, California

SafeWorld

Feb 2026 – present

  1. Oct 2026 – present

    Senior Machine Learning EngineerCurrent
  2. Feb 2026 – Aug 2026

    Founding Machine Learning Engineer

    Designed and built SafeWorld’s first human behavior modeling system from the ground up, enabling customers to simulate robot–human interactions and uncover risks before deployment. Contributed to AI-powered simulation and safety testing systems that help make robots safe around people.

More on LinkedIn